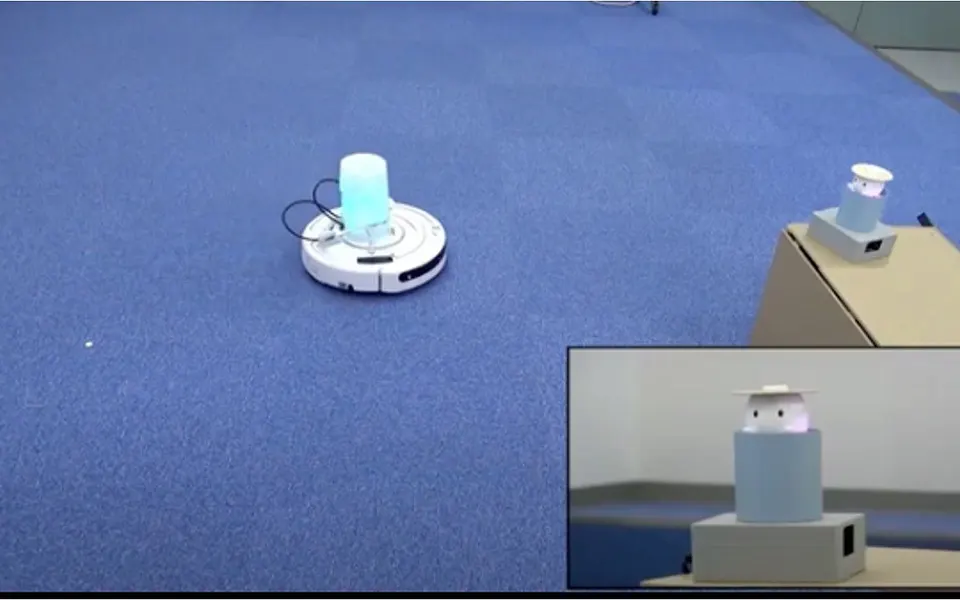
When eyes meet, how do people move?
Interpersonal Distance and Gaze Estimation with a Virtual Robot Head
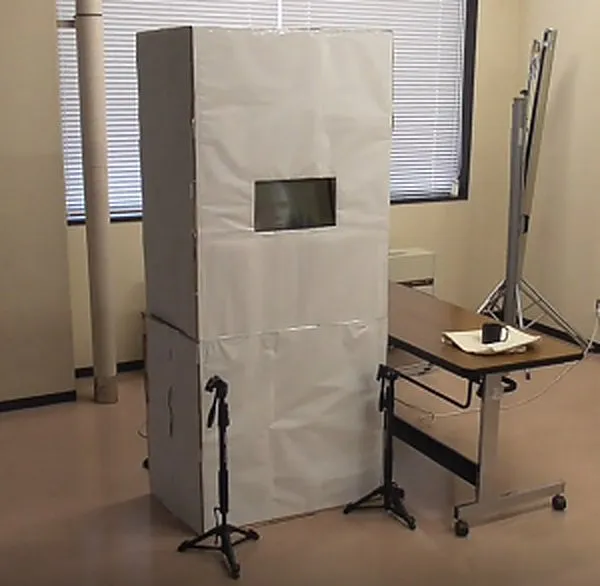
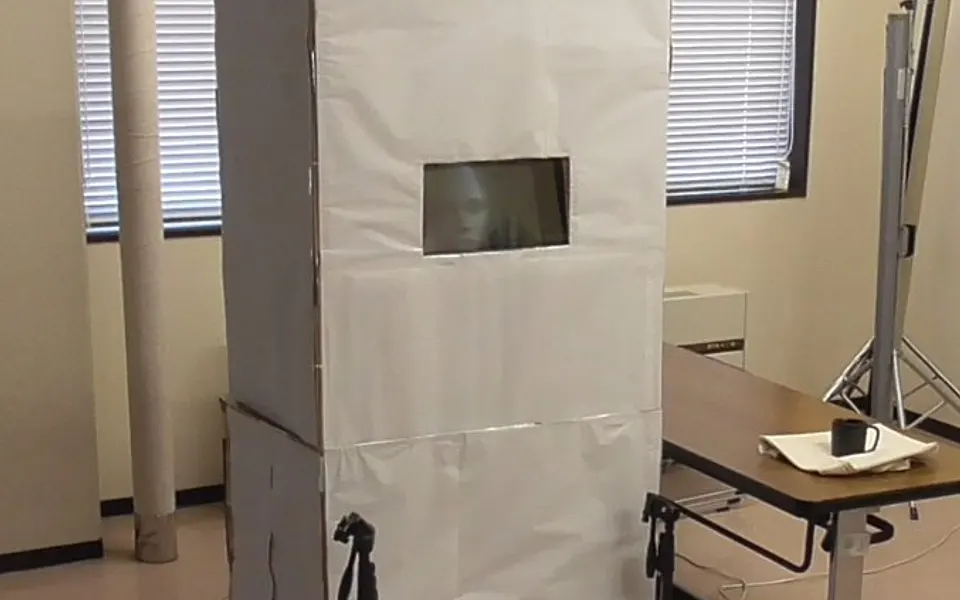
We developed a virtual robot head, a humanlike 3D model shown on a naked-eye stereoscopic display, and evaluated interpersonal distance and the accuracy of gaze estimation.
人間と同じような身体を持つ物理的なロボットが人とコミュニケーションを行う際の問題として、ロボットの動作が人を傷つける恐れがあることが挙げられます。そのため接近動作ができず、常に適切な対人距離を維持できるとは限りません。
身体動作の欠点を克服するため、平面ディスプレイに表示されるオンスクリーンエージェントを使用することが検討されてきましたが、モナリザ効果が発生するため、観察者が視点を変えてもエージェントから見つめられているように感じてしまう問題があります。
本研究ではこれらの問題を解決するため、裸眼立体視が可能なディスプレイ上に人型の 3D モデルを表示する「バーチャルロボットヘッド」を開発しました。
Figures
Related publications
-
2024
Lecture Notes in Computer Science
-
2024
バーチャルロボットヘッドにおける観察者の対人距離及び印象分析
HAIシンポジウム2024
-
2021
Journal of Japan Society for Fuzzy Theory and Intelligent Informatics
-
2021
Accuracy of Social Distance and Line of Sight Between a Virtual Robot Head and Humans
HAIシンポジウム2021
-
2020
IEEE International Conference on Robot and Human Interactive Communication (RO-MAN)